Simple Arduino 4WD Robot Car With L298N and IR Remote
6.000,00 EGP
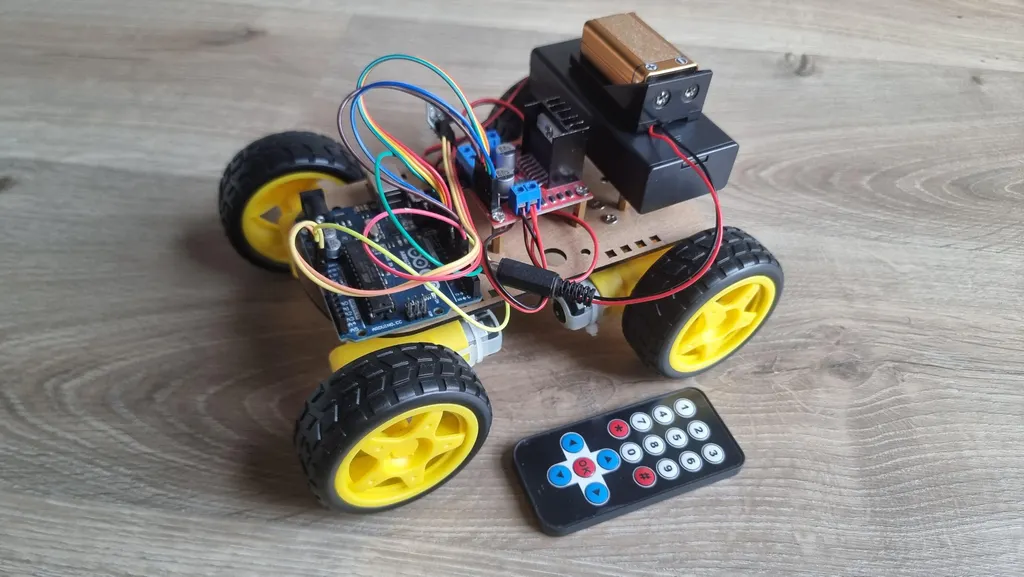
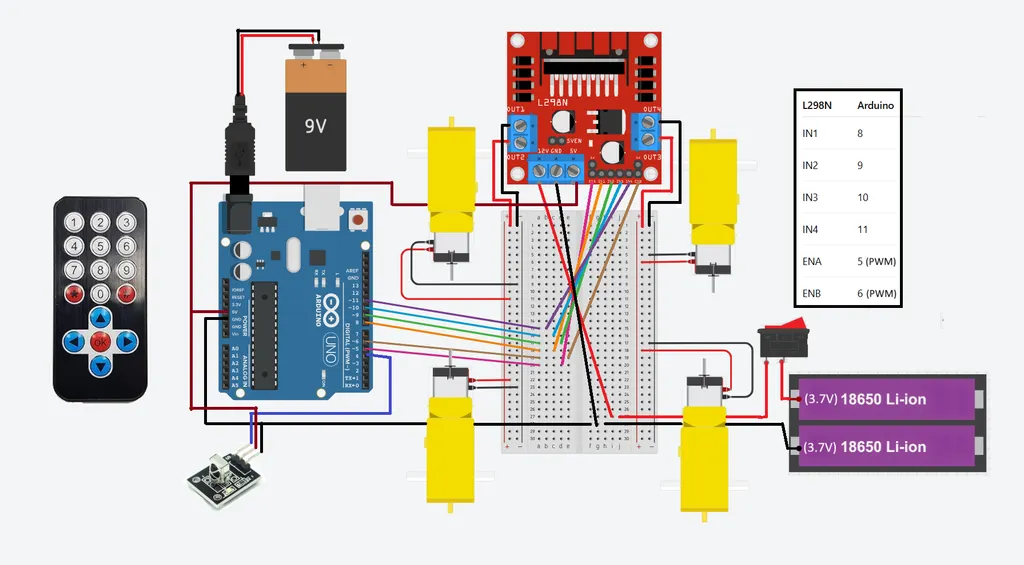
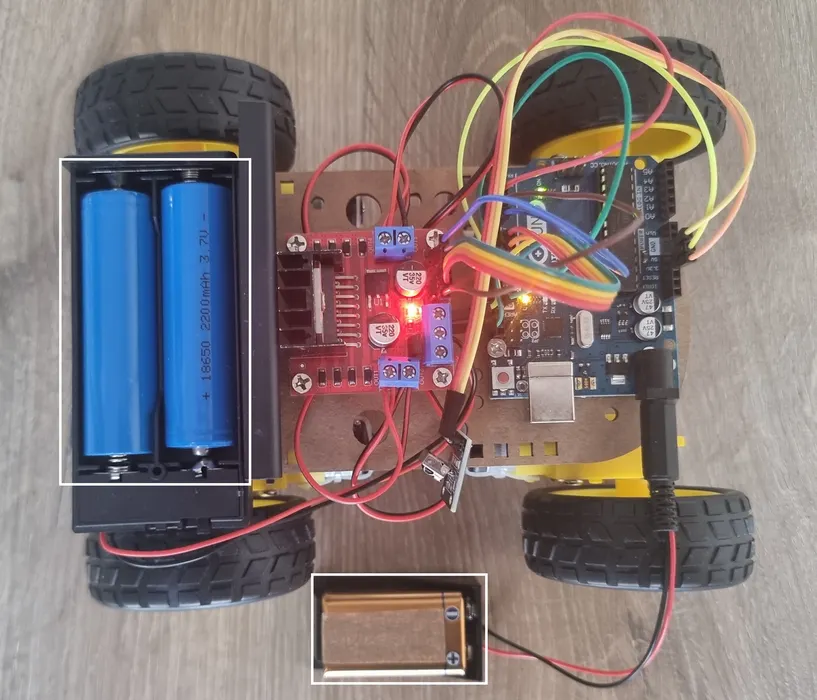
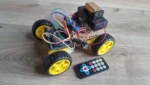
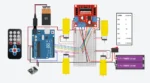
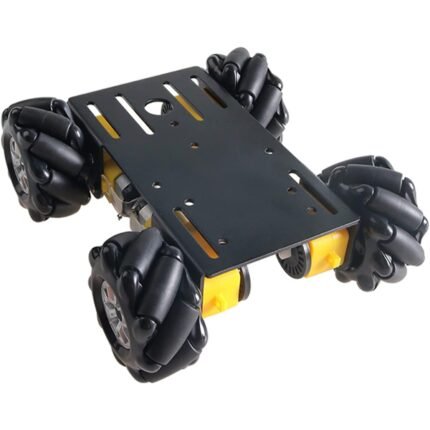
simple 4-wheel robotic car (V1.0) using four DC motors, an Arduino Uno, and an L298N motor driver.
The motor speed is fixed in this first version, and the project focuses only on basic movement control. The robot can move forward, backward, turn left, turn right, and stop. Control is achieved using an infrared (IR) remote, making the system easy to understand and simple to implement.
This project is especially suitable for beginners who want to learn how to control DC motors with Arduino without dealing with speed regulation or complex control algorithms.
It is a great introduction to mobile robotics, motor drivers, and infrared communication with Arduino. It also provides a solid foundation that can be extended later by adding features such as speed control, sensors, or alternative control methods.
By the end of this tutorial, you will have a functional and reliable robot car that performs essential movements using a clear and straightforward logic. This version (V1.0) serves as the base for future improvements.
Reviews
There are no reviews yet.